RobotRegistry › Robots › Wheeled / upper-body humanoid › PAL TIAGo PAL TIAGo The PAL TIAGo is a wheeled / upper-body humanoid from PAL Robotics (Barcelona, ES), shipping. ROS 1. Verified 24 Sept 2026.
‹ ›
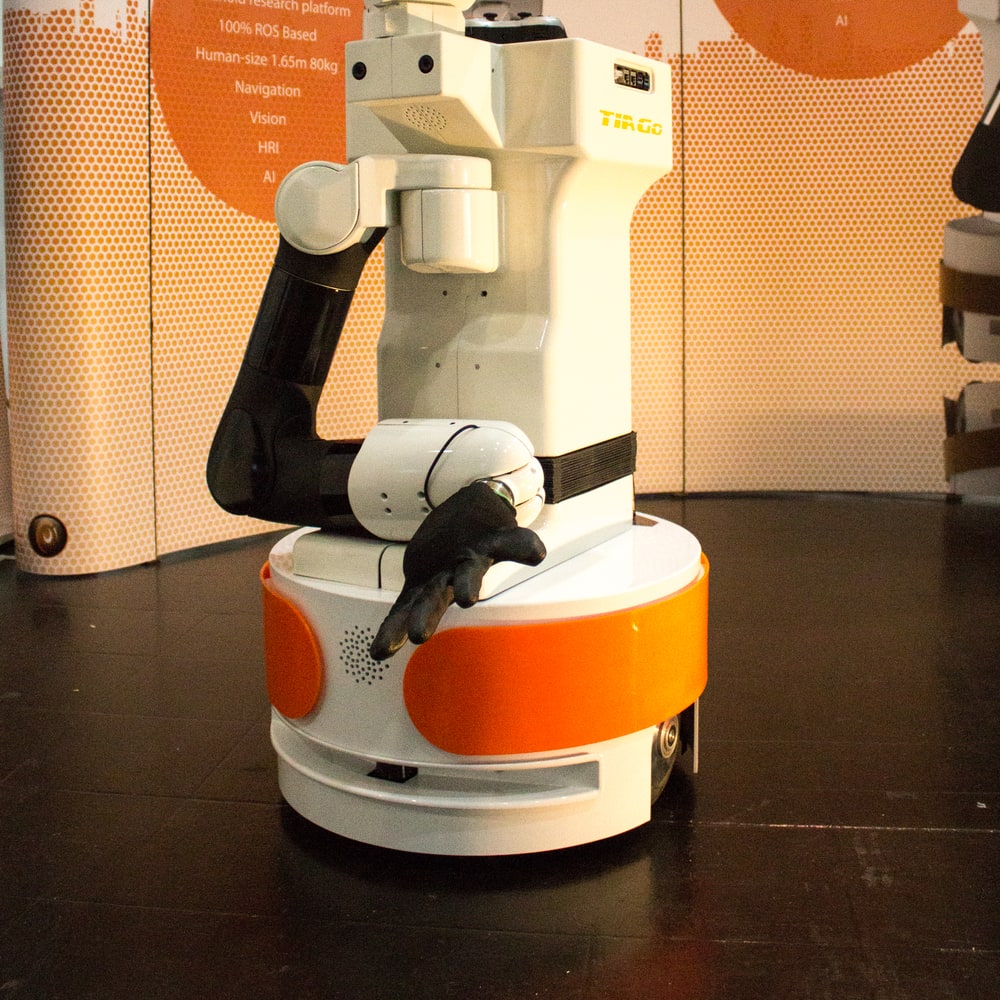
Photo: ubahnverleih · CC0 · original · cropped Would you want this robot? Yes No
No votes yet. Be the first. Reader poll · not a measurement · one vote per browser
‹ ›
Photo: ubahnverleih · CC0 · original · cropped Claims
17 accepted · 0 in review
Attribute · value Evidence · source · date
Commercial
Status
shipping
Evidence ▾ pal-robotics.com ·
source ↗ With over 9 years in the market, TIAGo is a popular choice for market leaders Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ With over 9 years in the market, TIAGo is a popular choice for market leaders Accessed 24 Sept 2026
Pricing type
quote only
Evidence ▾ pal-robotics.com ·
source ↗ The mobile manipulator robot that adapts to your research needs.
Request a quote Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ The mobile manipulator robot that adapts to your research needs.
Request a quote Accessed 24 Sept 2026
Warranty
1 year warranty on hardware, extendable
Evidence ▾ pal-robotics.com ·
source ↗ The mobile manipulator robot has 1 year warranty on hardware. The warranty for your TIAGo can be extended according to your need. Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ The mobile manipulator robot has 1 year warranty on hardware. The warranty for your TIAGo can be extended according to your need. Accessed 24 Sept 2026
Physical
Heightm
1.45 m
Evidence ▾ pal-robotics.com ·
source ↗ SPECS
Height
110-145 cm
Footprint Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ SPECS
Height
110-145 cm
Footprint Accessed 24 Sept 2026
Payloadkg · higher is better
3 kg
Evidence ▾ pal-robotics.com ·
source ↗ Arm Payload
3 Kg (without end-effector)
Battery autonomy Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Arm Payload
3 Kg (without end-effector)
Battery autonomy Accessed 24 Sept 2026
Runtimemin · higher is better
300 min
Evidence ▾ pal-robotics.com ·
source ↗ Battery autonomy
4-5 h (1 battery)/8-10h (2 batteries) Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Battery autonomy
4-5 h (1 battery)/8-10h (2 batteries) Accessed 24 Sept 2026
Hand type
Interchangeable end-effectors: parallel gripper (2F-140, 2F-85), ePick, Pal gripper, Hey5 hand
Evidence ▾ pal-robotics.com ·
source ↗ End-Effectors
Parallel
2F-140
2F-85
ePick
Pal Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ End-Effectors
Parallel
2F-140
2F-85
ePick
Pal Accessed 24 Sept 2026
Technical
Sensors
Hokuyo laser (5.6m range) · SICK TiM561 laser (10m range) · SICK TiM561 laser (25m range) · Torque sensor (optional) · 6-axis Force/Torque sensor (optional)
Evidence ▾ pal-robotics.com ·
source ↗ Lasers
Hokuyo - 5.6m range
Hokuyo - 5.6m range
SICK TiM561 - 10m range
SICK TiM561 - 10m range
SICK TiM561 - 25m range Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Lasers
Hokuyo - 5.6m range
Hokuyo - 5.6m range
SICK TiM561 - 10m range
SICK TiM561 - 10m range
SICK TiM561 - 25m range Accessed 24 Sept 2026
Lidar
Yes
Evidence ▾ pal-robotics.com ·
source ↗ Lasers
Hokuyo - 5.6m range
Hokuyo - 5.6m range
SICK TiM561 - 10m range Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Lasers
Hokuyo - 5.6m range
Hokuyo - 5.6m range
SICK TiM561 - 10m range Accessed 24 Sept 2026
Compute
Standard: Intel i5 CPU, 8 GB RAM, 250 GB SSD; Upgraded: Intel i7 CPU, 16 GB RAM, 500 GB SSD; NVIDIA Jetson add-on
Evidence ▾ pal-robotics.com ·
source ↗ Standard (Intel i5 CPU | 8 GB RAM | 250 GB SSD)
Standard (Intel i5 CPU | 8 GB RAM | 250 GB SSD)
Upgraded (Intel i7 CPU | 16 GB RAM | 500 GB SSD) Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Standard (Intel i5 CPU | 8 GB RAM | 250 GB SSD)
Standard (Intel i5 CPU | 8 GB RAM | 250 GB SSD)
Upgraded (Intel i7 CPU | 16 GB RAM | 500 GB SSD) Accessed 24 Sept 2026
Operating system
Ubuntu LTS, Real Time OS
Evidence ▾ pal-robotics.com ·
source ↗ OS
Ubuntu LTS, Real Time OS
OPEN SOURCE Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ OS
Ubuntu LTS, Real Time OS
OPEN SOURCE Accessed 24 Sept 2026
Software
ROS support
ros1
Evidence ▾ pal-robotics.com ·
source ↗ Coming soon! TIAGo the mobile manipulator in ROS 2 Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Coming soon! TIAGo the mobile manipulator in ROS 2 Accessed 24 Sept 2026
API type
ROS interfaces (ros control plugins, ros controllers)
Evidence ▾ pal-robotics.com ·
source ↗ The different motors of the mobile manipulator robot can be controlled using ROS interfaces. All the controllers provided are implemented as plugins of ros_control Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ The different motors of the mobile manipulator robot can be controlled using ROS interfaces. All the controllers provided are implemented as plugins of ros_control Accessed 24 Sept 2026
Simulators
open source ROS simulation (Docker image)
Evidence ▾ pal-robotics.com ·
source ↗ Get started right away with TIAGo’s open source simulation. Download a Docker image and try out TIAGo’s navigation and manipulation capabilities. Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ Get started right away with TIAGo’s open source simulation. Download a Docker image and try out TIAGo’s navigation and manipulation capabilities. Accessed 24 Sept 2026
Developer docs
wiki.ros.org/Robots/TIAGo
Evidence ▾ pal-robotics.com ·
source ↗ TIAGo simulation model and tutorials available at: wiki.ros.org/Robots/TIAGo Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ TIAGo simulation model and tutorials available at: wiki.ros.org/Robots/TIAGo Accessed 24 Sept 2026
Capability
Use cases
research · healthcare · education
Evidence ▾ pal-robotics.com ·
source ↗ We aim to reshape patient care by integrating latest robotic technologies to enhance healthcare efficiency and outcomes. Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ We aim to reshape patient care by integrating latest robotic technologies to enhance healthcare efficiency and outcomes. Accessed 24 Sept 2026
Target market
research
Evidence ▾ pal-robotics.com ·
source ↗ TIAGo is ready to be your best research companion! Combining perception, navigation, manipulation, and Human-Robot Interaction in a modular and friendly design Accessed 24 Sept 2026
pal-robotics.com ·
source ↗ TIAGo is ready to be your best research companion! Combining perception, navigation, manipulation, and Human-Robot Interaction in a modular and friendly design Accessed 24 Sept 2026
24 Sept 2026 Use cases research · healthcare · education
24 Sept 2026 Target market research
24 Sept 2026 Hand type Interchangeable end-effectors: parallel gripper (2F-140, 2F-85), ePick, Pal gripper, Hey5 hand
24 Sept 2026 Developer docs wiki.ros.org/Robots/TIAGo
24 Sept 2026 Simulators open source ROS simulation (Docker image)
24 Sept 2026 Warranty 1 year warranty on hardware, extendable
24 Sept 2026 Compute Standard: Intel i5 CPU, 8 GB RAM, 250 GB SSD; Upgraded: Intel i7 CPU, 16 GB RAM, 500 GB SSD; NVIDIA Jetson add-on
24 Sept 2026 Sensors Hokuyo laser (5.6m range) · SICK TiM561 laser (10m range) · SICK TiM561 laser (25m range) · Torque sensor (optional) · 6-axis Force/Torque sensor (optional)
Related · Wheeled / upper-body humanoid Compare with PAL TIAGo
Not affiliated with PAL Robotics. JSON: /api/robots/pal-tiago · Data CC BY 4.0 · Report an error