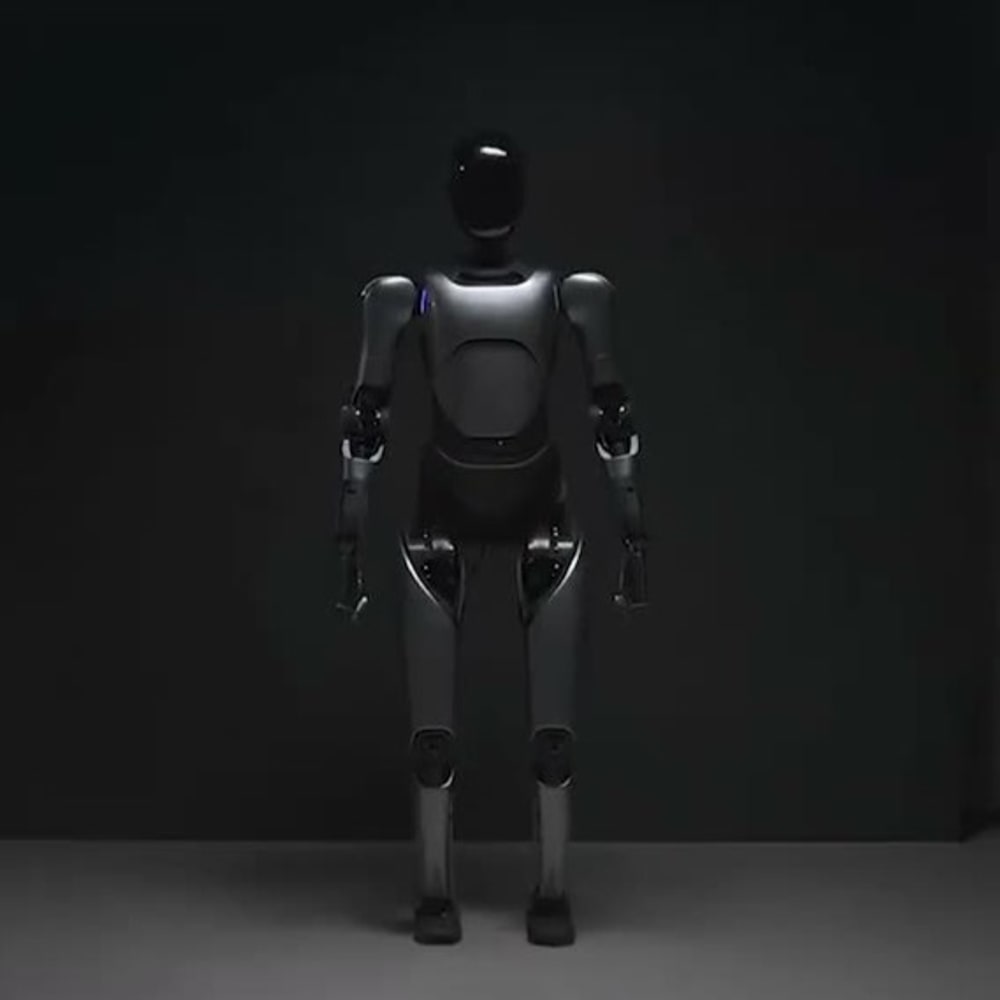
Pudu D9
The Pudu D9 is a 1.7 m, 65 kg full-size humanoid from Pudu Robotics (Shenzhen, CN). Verified 25 Sept 2026.
Frame from video by AITech3000 · Creative Commons Attribution license (reuse allowed) · original · croppedWould you want this robot?
No votes yet. Be the first. Reader poll · not a measurement · one vote per browser
Frame from video by AITech3000 · Creative Commons Attribution license (reuse allowed) · original · croppedClaims
11 accepted · 0 in review
Attribute · valueEvidence · source · date
Physical
Heightm
1.7 m
Evidence ▾
pudurobotics.com ·
source ↗Height
170 cm (66.93 inches)
Weight
65 kg (143.30 pounds)
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Height
170 cm (66.93 inches)
Weight
65 kg (143.30 pounds)
Accessed 24 Sept 2026
Weightkg
65 kg
Evidence ▾
pudurobotics.com ·
source ↗Weight
65 kg (143.30 pounds)
Leg Length
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Weight
65 kg (143.30 pounds)
Leg Length
Accessed 24 Sept 2026
Payloadkg · higher is better
20 kg
Evidence ▾
pudurobotics.com ·
source ↗Maximum Payload
20 kg (44.09 pounds) Single-arm 10 kg (22.05 pounds) (Testing Environment)
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Maximum Payload
20 kg (44.09 pounds) Single-arm 10 kg (22.05 pounds) (Testing Environment)
Accessed 24 Sept 2026
Max speedm/s · higher is better
2 m/s
Evidence ▾
pudurobotics.com ·
source ↗2 m/s
Maximum Walking Speed
High-Precision End Effector
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗2 m/s
Maximum Walking Speed
High-Precision End Effector
Accessed 24 Sept 2026
Battery capacityWh · higher is better
720 Wh
Evidence ▾
pudurobotics.com ·
source ↗Battery
15 Ah (0.72 kWh)
Speaker
Stereo
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Battery
15 Ah (0.72 kWh)
Speaker
Stereo
Accessed 24 Sept 2026
Degrees of freedom
42
Evidence ▾
pudurobotics.com ·
source ↗Degrees of Freedom
Total DOF 42 Single-leg DOF 6 Single-arm DOF 7
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Degrees of Freedom
Total DOF 42 Single-leg DOF 6 Single-arm DOF 7
Accessed 24 Sept 2026
Hand DOF
11
Evidence ▾
pudurobotics.com ·
source ↗Equipped with the PUDU DH11, 11-degree-of-freedom dexterous hands, capable of performing a wide range of intricate tasks
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Equipped with the PUDU DH11, 11-degree-of-freedom dexterous hands, capable of performing a wide range of intricate tasks
Accessed 24 Sept 2026
Hand type
PUDU DH11 dexterous hand (12 tactile sensing regions, 6 active + 5 passive DOF)
Evidence ▾
pudurobotics.com ·
source ↗Dexterous Hand(PUDU DH11)
12 Tactile Sensing Regions Active DOF 6 Passive DOF 5
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Dexterous Hand(PUDU DH11)
12 Tactile Sensing Regions Active DOF 6 Passive DOF 5
Accessed 24 Sept 2026
Technical
Sensors
RGB · RGBD · Tactile sensors · IMU
Evidence ▾
pudurobotics.com ·
source ↗Sensors
RGB RGBD Tactile sensors IMU
Computing Power
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Sensors
RGB RGBD Tactile sensors IMU
Computing Power
Accessed 24 Sept 2026
Compute
275 TOPS
Evidence ▾
pudurobotics.com ·
source ↗Computing Power
275 TOPS
Battery
15 Ah (0.72 kWh)
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗Computing Power
275 TOPS
Battery
15 Ah (0.72 kWh)
Accessed 24 Sept 2026
Capability
Use cases
object manipulation · customer engagement
Evidence ▾
pudurobotics.com ·
source ↗PUDU D9 | Full-Sized Bipedal Humanoid Robot for Object Manipulation and Customer Engagement
Accessed 24 Sept 2026
pudurobotics.com ·
source ↗PUDU D9 | Full-Sized Bipedal Humanoid Robot for Object Manipulation and Customer Engagement
Accessed 24 Sept 2026
25 Sept 2026Use casesobject manipulation · customer engagement
25 Sept 2026Battery capacity720 Wh
25 Sept 2026Compute275 TOPS
25 Sept 2026SensorsRGB · RGBD · Tactile sensors · IMU
25 Sept 2026Max speed2 m/s
25 Sept 2026Payload20 kg
25 Sept 2026Hand typePUDU DH11 dexterous hand (12 tactile sensing regions, 6 active + 5 passive DOF)
25 Sept 2026Hand DOF11
Related · Full-size humanoidCompare with Pudu D9
Not affiliated with Pudu Robotics. JSON: /api/robots/pudu-d9 · Data CC BY 4.0 · Report an error