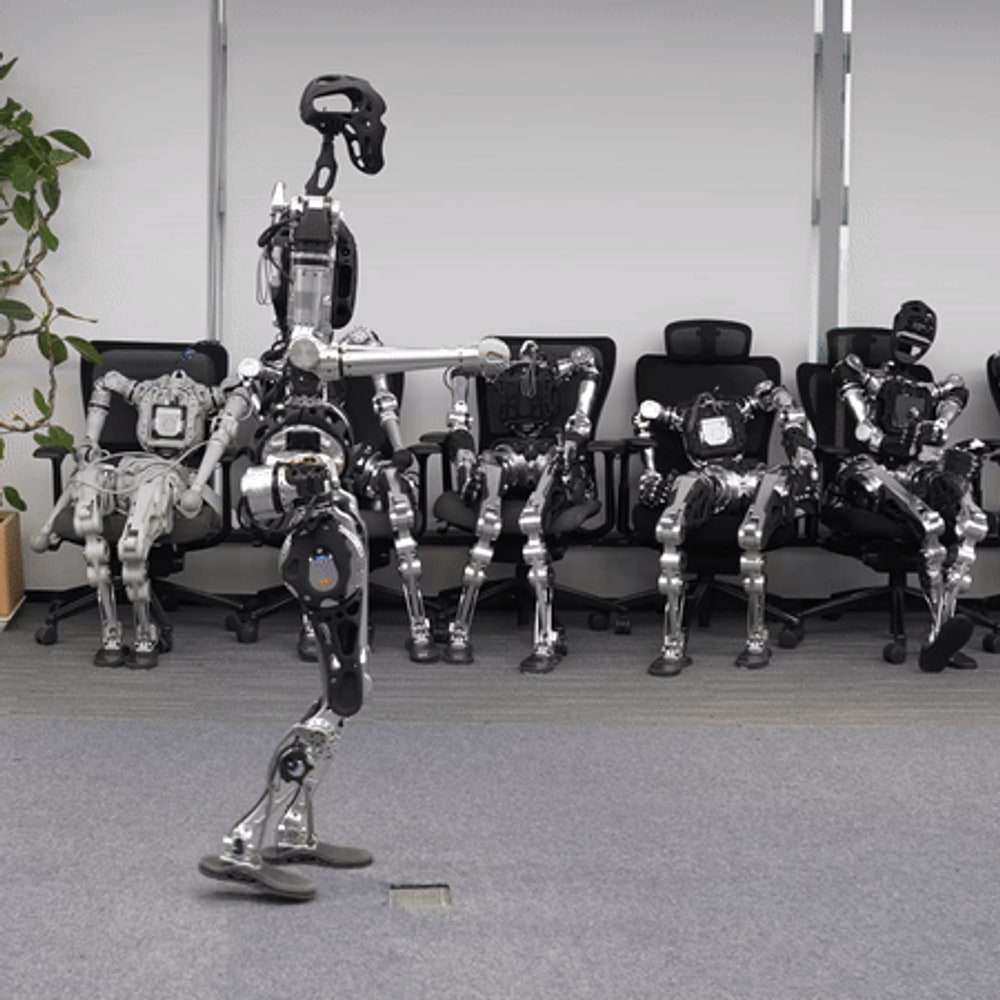
RobotRegistry › Robots › Full-size humanoid › Kepler K2 Kepler K2 The Kepler K2 is a 1.75 m, 75 kg full-size humanoid from Kepler Robotics (Shanghai, CN). Verified 25 Sept 2026.
Would you want this robot? Yes No
No votes yet. Be the first. Reader poll · not a measurement · one vote per browser
Claims
12 accepted · 0 in review
Attribute · value Evidence · source · date
Physical
Heightm
1.75 m
Evidence ▾ gotokepler.com ·
source ↗ title1:"KEPLERBOT Forerunner K2",title2:"",subTitle:"Kepler Forerunner Series General-Purpose Humanoid Robot",configurationVal1:"175 cm",configuration1:"Height" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ title1:"KEPLERBOT Forerunner K2",title2:"",subTitle:"Kepler Forerunner Series General-Purpose Humanoid Robot",configurationVal1:"175 cm",configuration1:"Height" Accessed 25 Sept 2026
Weightkg
75 kg
Evidence ▾ gotokepler.com ·
source ↗ configurationVal1:"175 cm",configuration1:"Height",configurationVal2:"52-DOF",configuration2:"Whole Body Control",configurationVal3:"75kg",configuration3:"Weight" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ configurationVal1:"175 cm",configuration1:"Height",configurationVal2:"52-DOF",configuration2:"Whole Body Control",configurationVal3:"75kg",configuration3:"Weight" Accessed 25 Sept 2026
Payloadkg · higher is better
25 kg
Evidence ▾ gotokepler.com ·
source ↗ configurationLeft:"Doual-arm collaborative handling",configurationValLeft:"25 -30 kg",configurationRight:"One-hour charging" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ configurationLeft:"Doual-arm collaborative handling",configurationValLeft:"25 -30 kg",configurationRight:"One-hour charging" Accessed 25 Sept 2026
Runtimemin · higher is better
480 min
Evidence ▾ gotokepler.com ·
source ↗ title2:"1-hour charge, 8 -hour endurance",subTitle:"KEPLERBOT Forerunner K2" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ title2:"1-hour charge, 8 -hour endurance",subTitle:"KEPLERBOT Forerunner K2" Accessed 25 Sept 2026
Degrees of freedom
52
Evidence ▾ gotokepler.com ·
source ↗ key:"Human-like full-body joints",val:"52 full-body DOF, 6-joint single leg, 7-joint single arm, 11-DOF single dexterous hand" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ key:"Human-like full-body joints",val:"52 full-body DOF, 6-joint single leg, 7-joint single arm, 11-DOF single dexterous hand" Accessed 25 Sept 2026
Hand DOF
11
Evidence ▾ gotokepler.com ·
source ↗ 52 full-body DOF, 6-joint single leg, 7-joint single arm, 11 -DOF single dexterous hand Accessed 25 Sept 2026
gotokepler.com ·
source ↗ 52 full-body DOF, 6-joint single leg, 7-joint single arm, 11 -DOF single dexterous hand Accessed 25 Sept 2026
Hand type
10-finger tactile dexterous hand
Evidence ▾ gotokepler.com ·
source ↗ subTitle1:"10-finger tactile dexterous hand : heavy loads, long endurance, rough & delicate tasks" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ subTitle1:"10-finger tactile dexterous hand : heavy loads, long endurance, rough & delicate tasks" Accessed 25 Sept 2026
Technical
Sensors
Flexible sensors · 6-axis force sensors · pure vision system · inertial sensors
Evidence ▾ gotokepler.com ·
source ↗ key:"Human-like perception",val:"Flexible sensors, 6-axis force sensors, pure vision system, inertial sensors " Accessed 25 Sept 2026
gotokepler.com ·
source ↗ key:"Human-like perception",val:"Flexible sensors, 6-axis force sensors, pure vision system, inertial sensors " Accessed 25 Sept 2026
Compute
275 TOPS Computing Power
Evidence ▾ gotokepler.com ·
source ↗ configurationVal3:"75kg",configuration3:"Weight",configurationVal4:"275 TOPS Computing Power ",configuration4:"Computing Power per Second" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ configurationVal3:"75kg",configuration3:"Weight",configurationVal4:"275 TOPS Computing Power ",configuration4:"Computing Power per Second" Accessed 25 Sept 2026
AI stack
KEPLER Embodied AI, hierarchical end-to-end neural stack (Perception, Neural Decision, Actuation layers)
Evidence ▾ gotokepler.com ·
source ↗ content:"Hierarchical Architecture breaks tasks into Perception → Neural Decision → Actuation layers for millimeter-precision motion." Accessed 25 Sept 2026
gotokepler.com ·
source ↗ content:"Hierarchical Architecture breaks tasks into Perception → Neural Decision → Actuation layers for millimeter-precision motion." Accessed 25 Sept 2026
Capability
Use cases
Factory sector
Evidence ▾ gotokepler.com ·
source ↗ p2:{title1:"Leading Humanoid Robots for Factory Sector ",title2:"Leadership" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ p2:{title1:"Leading Humanoid Robots for Factory Sector ",title2:"Leadership" Accessed 25 Sept 2026
Target market
industrial
Evidence ▾ gotokepler.com ·
source ↗ p2:{title1:"Leading Humanoid Robots for Factory Sector",title2:"Leadership" Accessed 25 Sept 2026
gotokepler.com ·
source ↗ p2:{title1:"Leading Humanoid Robots for Factory Sector",title2:"Leadership" Accessed 25 Sept 2026
25 Sept 2026 AI stack KEPLER Embodied AI, hierarchical end-to-end neural stack (Perception, Neural Decision, Actuation layers)
25 Sept 2026 Target market industrial
25 Sept 2026 Use cases Factory sector
25 Sept 2026 Payload 25 kg
25 Sept 2026 Sensors Flexible sensors · 6-axis force sensors · pure vision system · inertial sensors
25 Sept 2026 Compute 275 TOPS Computing Power
25 Sept 2026 Runtime 480 min
25 Sept 2026 Hand type 10-finger tactile dexterous hand
Related · Full-size humanoid Compare with Kepler K2
Not affiliated with Kepler Robotics. JSON: /api/robots/kepler-k2 · Data CC BY 4.0 · Report an error