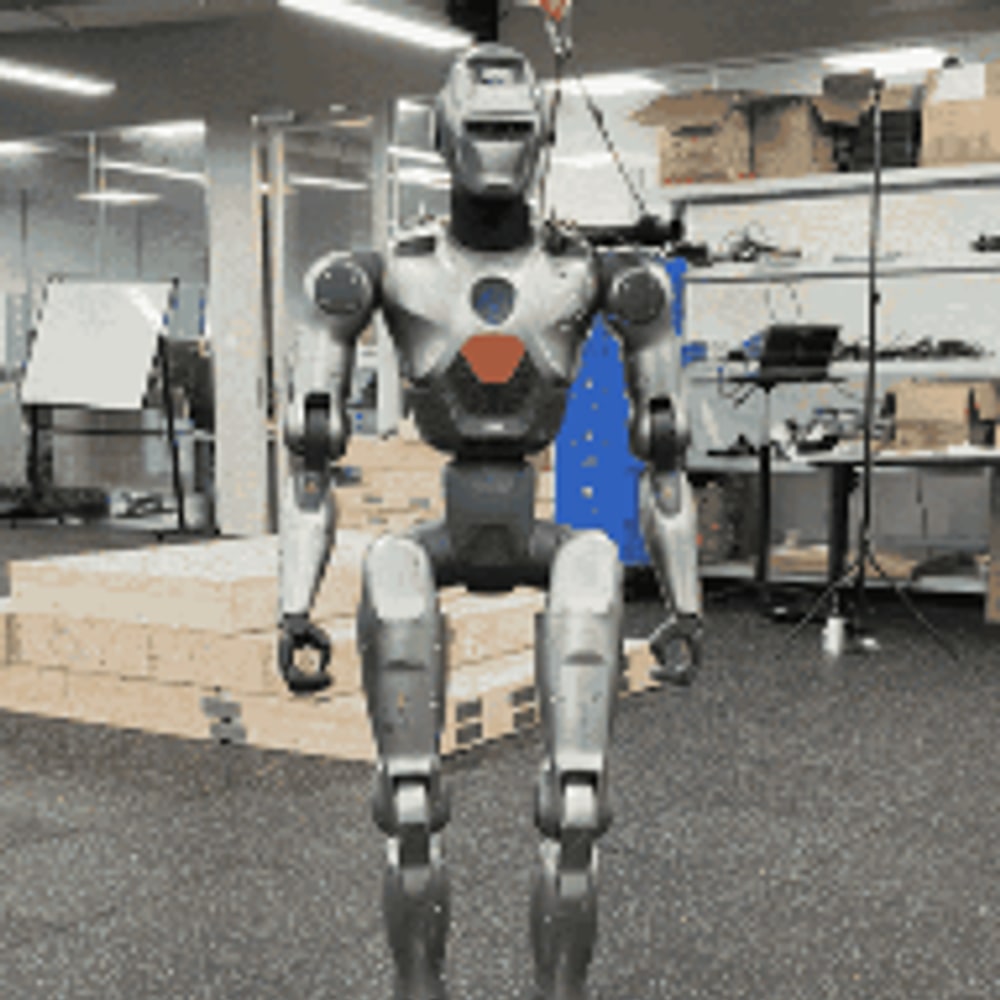
RobotRegistry › Robots › Compact humanoid › iCub iCub The iCub is a 1.05 m, 33 kg compact humanoid from Istituto Italiano di Tecnologia (Genoa, IT), shipping, from EUR 250,000. ROS 2, Python · Java · C# · Matlab SDK. Verified 25 Sept 2026.
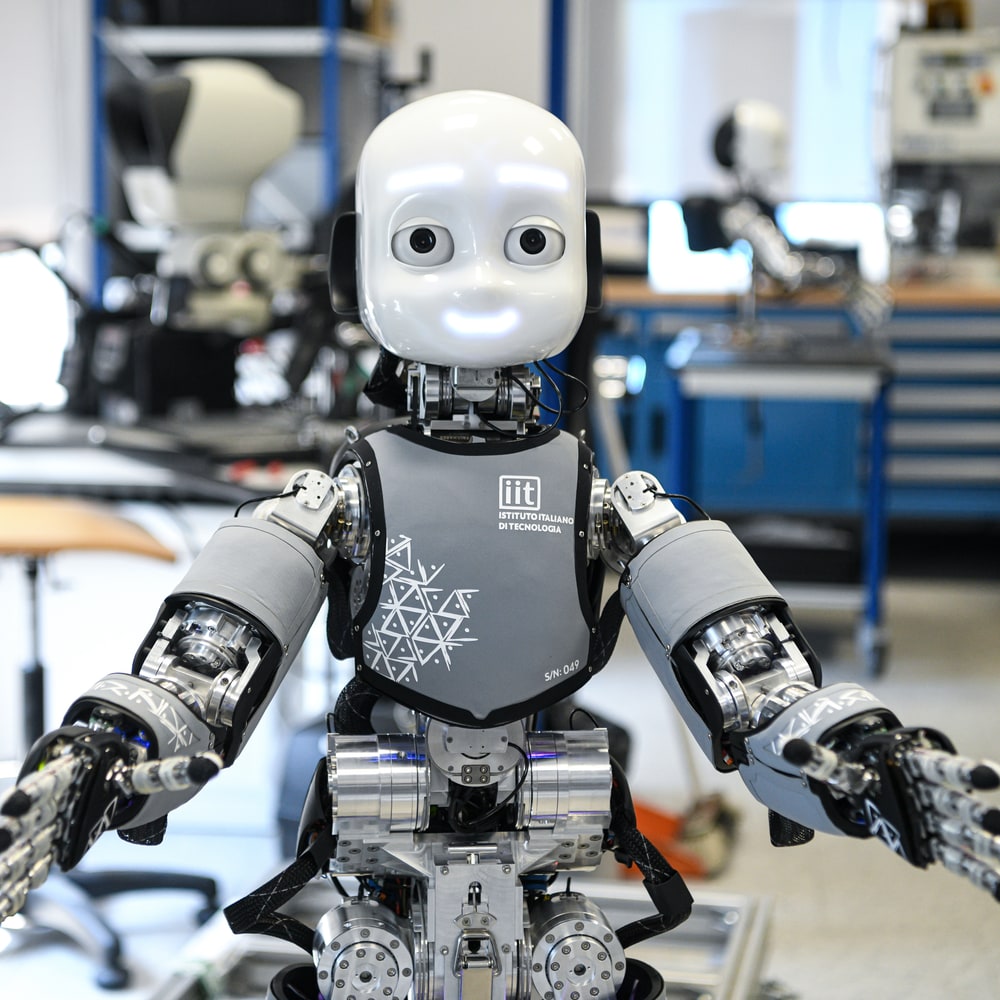
Photo: Piero Cruciatti - European Commission · CC BY 4.0 · original · cropped Would you want this robot? Yes No
No votes yet. Be the first. Reader poll · not a measurement · one vote per browser
Photo: Piero Cruciatti - European Commission · CC BY 4.0 · original · cropped List price · US
EUR 250,000
Claims
19 accepted · 0 in review
Attribute · value Evidence · source · date
Commercial
Status
shipping
Evidence ▾ The iCub can be obtained from the Istituto Italiano di Tecnologia for a fee (indicative prices are shown below). Accessed 25 Sept 2026
The iCub can be obtained from the Istituto Italiano di Tecnologia for a fee (indicative prices are shown below). Accessed 25 Sept 2026
List priceUSD · lower is better
EUR 250,000
Evidence ▾ The indicative costs to build a full iCub amount to 250,000 Euros. Accessed 25 Sept 2026
The indicative costs to build a full iCub amount to 250,000 Euros. Accessed 25 Sept 2026
Pricing type
quote only
Evidence ▾ For official quotations or general enquiries about the iCub please contact Giorgio Metta Accessed 25 Sept 2026
For official quotations or general enquiries about the iCub please contact Giorgio Metta Accessed 25 Sept 2026
Physical
Heightm
1.05 m
Evidence ▾ Body Height ~105 cm Width 36.5 cm Accessed 25 Sept 2026
Body Height ~105 cm Width 36.5 cm Accessed 25 Sept 2026
Weightkg
33 kg
Evidence ▾ Weight: 33 kg (30kg + 3kg battery backpack) Accessed 25 Sept 2026
Weight: 33 kg (30kg + 3kg battery backpack) Accessed 25 Sept 2026
Degrees of freedom
53
Evidence ▾ The total number of degrees of freedom is 53 . Accessed 25 Sept 2026
The total number of degrees of freedom is 53 . Accessed 25 Sept 2026
Hand DOF
9
Evidence ▾ 53 motors, 9 degrees of freedom in each hand Accessed 25 Sept 2026
53 motors, 9 degrees of freedom in each hand Accessed 25 Sept 2026
Hand type
Five-finger dexterous hand, nine motors driving tendons, 3-DoF wrist, tactile sensors in palm and fingertips
Evidence ▾ The iCub hand is a dexterous hand with five fingers actuated by nine motors through a set of tendons. Accessed 25 Sept 2026
The iCub hand is a dexterous hand with five fingers actuated by nine motors through a set of tendons. Accessed 25 Sept 2026
Technical
Sensors
2 cameras (Pointgrey Dragonfly 2, 640x480) in the eyes · 2 stereo omnidirectional microphones · inertial sensors (3-axis gyroscope, accelerometer and geomagnetic, BOSCH BNO055) · absolute magnetic and incremental joint encoders · 6 six-axis force/torque sensors plus 2 ankle sensors · more than 3000 capacitive tactile sensors (skin)
Evidence ▾ Cameras 2 Mounted in the eyes (see above), Pointgrey Dragonfly 2 (640x480)
Microphones 2 SoundMan High quality Stereo Omnidirectional microphone Accessed 25 Sept 2026
Cameras 2 Mounted in the eyes (see above), Pointgrey Dragonfly 2 (640x480)
Microphones 2 SoundMan High quality Stereo Omnidirectional microphone Accessed 25 Sept 2026
Cameras
2 x Pointgrey Dragonfly 2 (640x480) mounted in the eyes
Evidence ▾ Cameras 2 Mounted in the eyes (see above), Pointgrey Dragonfly 2 (640x480) Accessed 25 Sept 2026
Cameras 2 Mounted in the eyes (see above), Pointgrey Dragonfly 2 (640x480) Accessed 25 Sept 2026
Compute
Intel i7 7600 CPU, 4 GB RAM, 32GB SSD
Evidence ▾ On board Computer CPU Intel i7 7600
RAM 4 GB
SSD 32GB Accessed 25 Sept 2026
On board Computer CPU Intel i7 7600
RAM 4 GB
SSD 32GB Accessed 25 Sept 2026
AI stack
iCub software repository: kinematics and dynamics, force/impedance control, reaching and grasping behaviours, attention system, online object learning and recognition, speech interfaces, OpenCV, Point Cloud
Evidence ▾ - Attention system;
- Object learning and recognition
(online);
- Speech interfaces Accessed 25 Sept 2026
- Attention system;
- Object learning and recognition
(online);
- Speech interfaces Accessed 25 Sept 2026
Operating system
Ubuntu LTS 64 bits
Evidence ▾ Operating System Ubuntu LTS 64 bits Accessed 25 Sept 2026
Operating System Ubuntu LTS 64 bits Accessed 25 Sept 2026
Software
ROS support
ros2
Evidence ▾ mesh-iit.github.io ·
source ↗ Using iCub or ergoCub with ROS 2 Accessed 25 Sept 2026
mesh-iit.github.io ·
source ↗ Using iCub or ergoCub with ROS 2 Accessed 25 Sept 2026
SDK available
Yes
Evidence ▾ All source code is available from the GIT
repository (https://github.com/robotology) Accessed 25 Sept 2026
All source code is available from the GIT
repository (https://github.com/robotology) Accessed 25 Sept 2026
SDK languages
Python · Java · C# · Matlab
Evidence ▾ - Interfaces to various programming
languages (e.g. Python, Java, C#). Accessed 25 Sept 2026
- Interfaces to various programming
languages (e.g. Python, Java, C#). Accessed 25 Sept 2026
API type
YARP 3 middleware with interface to ROS
Evidence ▾ Middleware YARP 3, interface to ROS. Accessed 25 Sept 2026
Middleware YARP 3, interface to ROS. Accessed 25 Sept 2026
Developer docs
http://www.icub.org
Evidence ▾ All technical documentation is available from
the manual (www.icub.org) Accessed 25 Sept 2026
All technical documentation is available from
the manual (www.icub.org) Accessed 25 Sept 2026
Capability
Target market
research
Evidence ▾ We would like to promote high quality research through high quality robotics. Accessed 25 Sept 2026
We would like to promote high quality research through high quality robotics. Accessed 25 Sept 2026
25 Sept 2026 ROS support ros2
25 Sept 2026 Developer docs http://www.icub.org
25 Sept 2026 AI stack iCub software repository: kinematics and dynamics, force/impedance control, reaching and grasping behaviours, attention system, online object learning and recognition, speech interfaces, OpenCV, Point Cloud
25 Sept 2026 SDK languages Python · Java · C# · Matlab
25 Sept 2026 SDK available Yes
25 Sept 2026 API type YARP 3 middleware with interface to ROS
25 Sept 2026 Operating system Ubuntu LTS 64 bits
25 Sept 2026 Compute Intel i7 7600 CPU, 4 GB RAM, 32GB SSD
Related · Compact humanoid Compare with iCub
Not affiliated with Istituto Italiano di Tecnologia. JSON: /api/robots/iit-icub · Data CC BY 4.0 · Report an error