Compare · Compact humanoid · 2 of 4
EngineAI SE01 vs iCub
/compare/engineai-se01-vs-iit-icub · one URL per set, slugs sorted
 EngineAI SE01
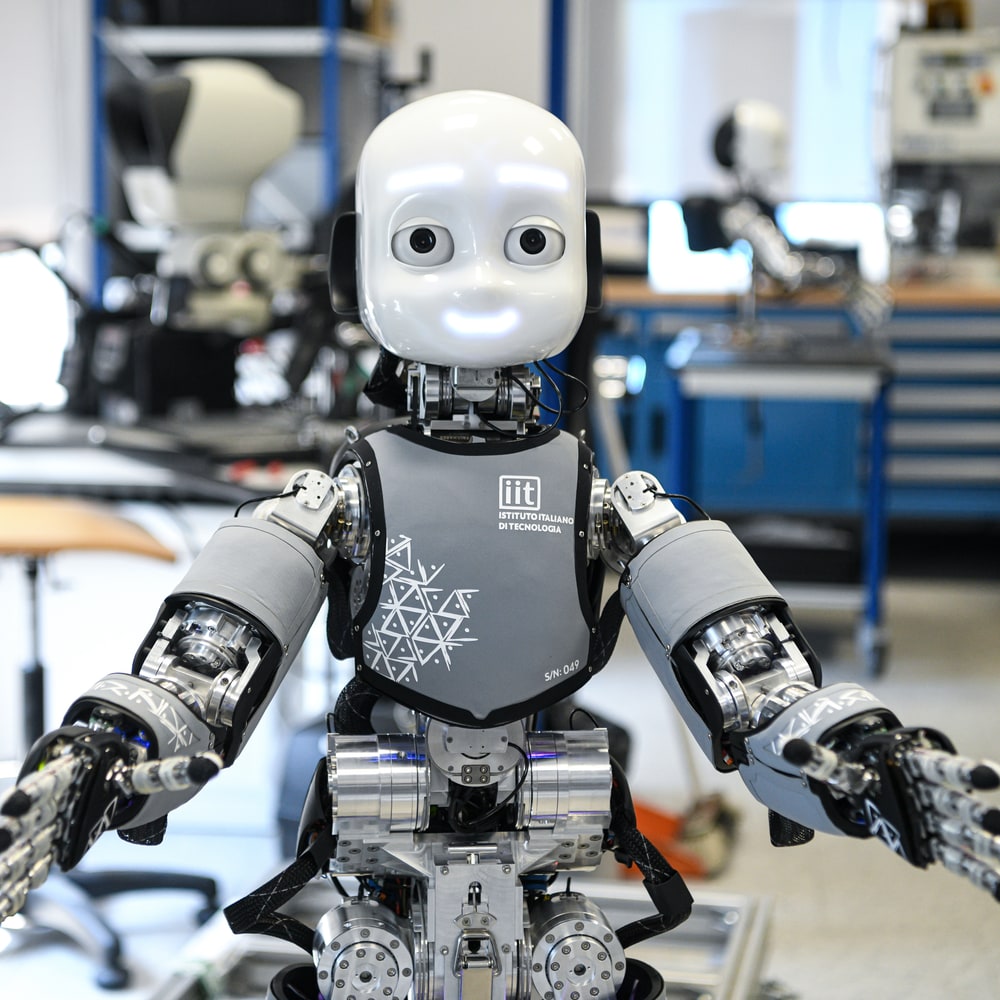 iCub
Physical
Hand DOFno better
6
Verified · T1
9
Verified · T1
Hand typeno better
bionic five-finger dexterous hand
Verified · T1
Five-finger dexterous hand, nine motors driving tendons, 3-DoF wrist, tactile sensors in palm and fingertips
Verified · T1
Technical
Sensorsno better
LiDAR · Depth Camera · Infrared Camera
Verified · T1
2 cameras (Pointgrey Dragonfly 2, 640x480) in the eyes · 2 stereo omnidirectional microphones · inertial sensors (3-axis gyroscope, accelerometer and geomagnetic, BOSCH BNO055) · absolute magnetic and incremental joint encoders · 6 six-axis force/torque sensors plus 2 ankle sensors · more than 3000 capacitive tactile sensors (skin)
Verified · T1
Camerasno better
Depth Camera · Infrared Camera
Verified · T1
2 x Pointgrey Dragonfly 2 (640x480) mounted in the eyes
Verified · T1
16 attributes are not compared because not every robot here reports them.
Wins by disclosed attributes with a defined better · SE01 0 · iCub 0 · 0 ties4 attributes have no better, are undisclosed or disputed · no overall winner is ever declared
Verified EngineAI SE01 25 Sept 2026 · iCub 25 Sept 2026