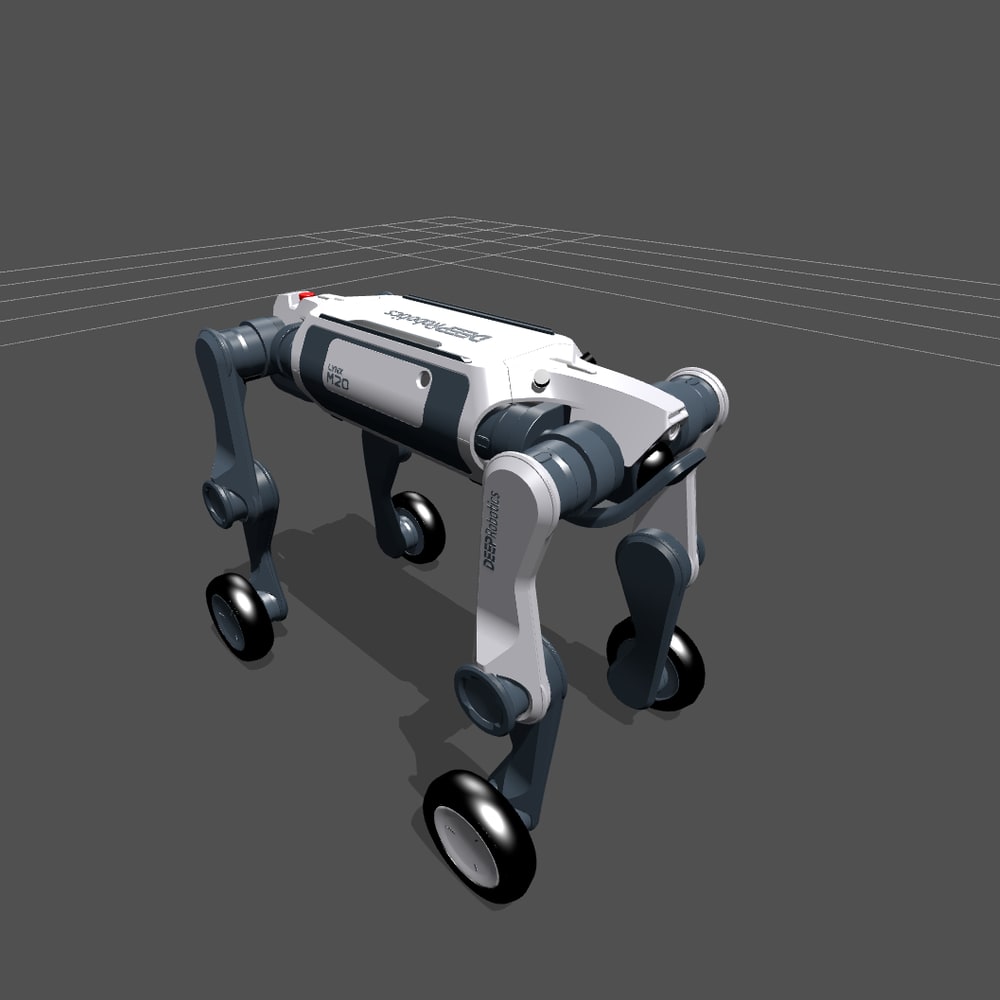
Unitree B2
宇树科技
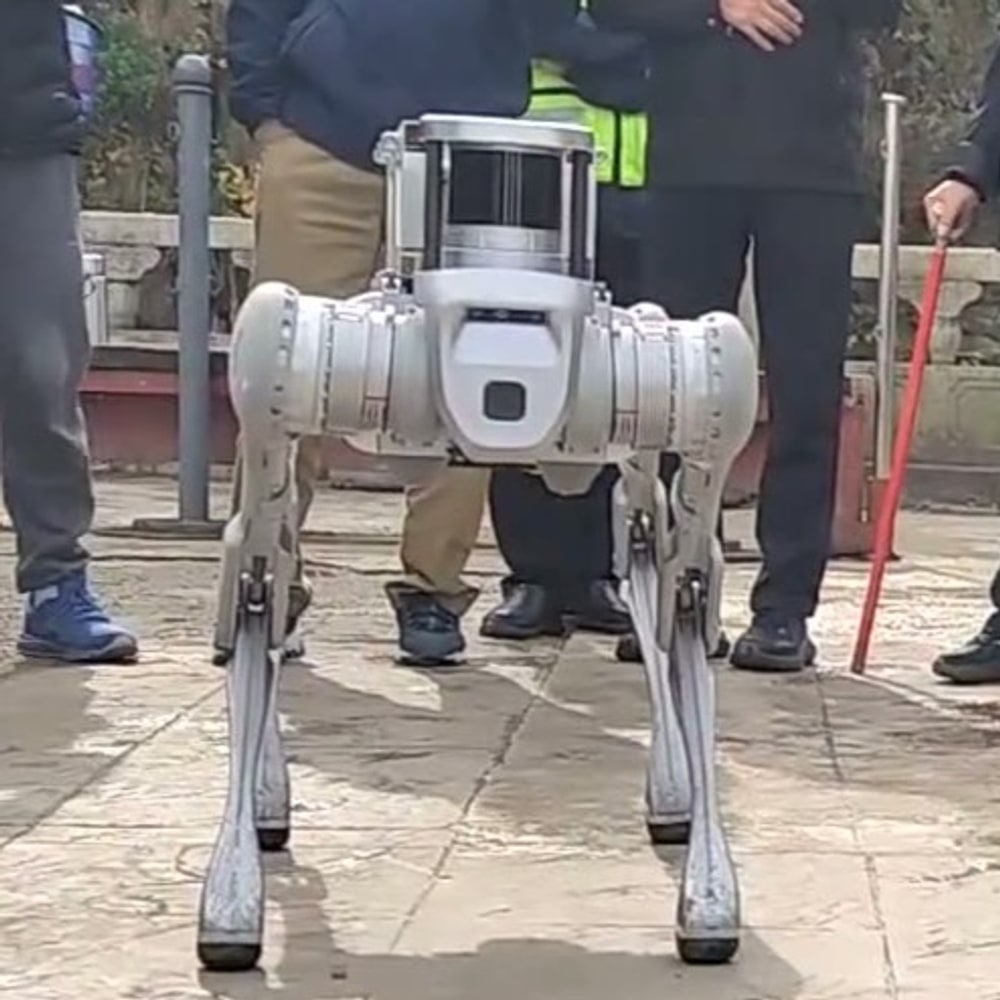
The Unitree B2 is a 0.645 m, 60 kg quadruped from Unitree Robotics (Hangzhou, CN). Verified 24 Sept 2026.
Frame from video by | · 20241022 · original · croppedWould you want this robot?
No votes yet. Be the first. Reader poll · not a measurement · one vote per browser
Frame from video by | · 20241022 · original · croppedClaims
11 accepted · 0 in review
Attribute · valueEvidence · source · date
Physical
Heightm
0.645 m
Evidence ▾
Size(Standing) ≈ 1098mm×450mm×645mm Size(Lying Prone) ≈ 880mm×460mm×330mm
Accessed 24 Sept 2026
Size(Standing) ≈ 1098mm×450mm×645mm Size(Lying Prone) ≈ 880mm×460mm×330mm
Accessed 24 Sept 2026
Weightkg
60 kg
Evidence ▾
Weight ≈ 60kg Total weight (battery included) Battery Performance
Accessed 24 Sept 2026
Weight ≈ 60kg Total weight (battery included) Battery Performance
Accessed 24 Sept 2026
Payloadkg · higher is better
40 kg
Evidence ▾
Ultra Load Standing load ≥120kg Continuous walking load >40kg Max Walking Capacity
Accessed 24 Sept 2026
Ultra Load Standing load ≥120kg Continuous walking load >40kg Max Walking Capacity
Accessed 24 Sept 2026
Runtimemin · higher is better
300 min
Evidence ▾
Endurance Ability Battery life 4-6h Walking without load > 5h, and the mileage > 20km
Accessed 24 Sept 2026
Endurance Ability Battery life 4-6h Walking without load > 5h, and the mileage > 20km
Accessed 24 Sept 2026
Battery capacityWh · higher is better
2250 Wh
Evidence ▾
Battery Performance Battery capacity 45Ah(2250Wh),voltage 58V Endurance Ability
Accessed 24 Sept 2026
Battery Performance Battery capacity 45Ah(2250Wh),voltage 58V Endurance Ability
Accessed 24 Sept 2026
Technical
Sensors
3D LiDAR · Depth camera · Optical camera
Evidence ▾
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Lidar
Yes
Evidence ▾
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Cameras
Depth camera ×2 · Optical camera ×2
Evidence ▾
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Sensing Sensor 3D LiDAR ×1 + Depth camera ×2 + Optical camera ×2 (Varies with different configurations)
Accessed 24 Sept 2026
Compute
Intel Core i5 (Platform Function), Intel Core i7 (User Development)
Evidence ▾
Standard Configuration: Intel Core i5 (Platform Function), Intel Core i7 (User Development)
Accessed 24 Sept 2026
Standard Configuration: Intel Core i5 (Platform Function), Intel Core i7 (User Development)
Accessed 24 Sept 2026
Capability
Use cases
Power Inspection · Emergency Rescue · Industrial Inspection
Evidence ▾
Steep Slopes, etc. —— Emergency Rescue Infrared Scanning 3DMapping Optimized Environmental Perception —— Industrial Inspection Intelligent Power Solutions Industry Application Leader —— Power Inspection
Accessed 24 Sept 2026
Steep Slopes, etc. —— Emergency Rescue Infrared Scanning 3DMapping Optimized Environmental Perception —— Industrial Inspection Intelligent Power Solutions Industry Application Leader —— Power Inspection
Accessed 24 Sept 2026
Target market
industrial
Evidence ▾
Fastest running industrial-grade quadruped robot at 6m/s [1]
Accessed 24 Sept 2026
Fastest running industrial-grade quadruped robot at 6m/s [1]
Accessed 24 Sept 2026
24 Sept 2026Target marketindustrial
24 Sept 2026Use casesPower Inspection · Emergency Rescue · Industrial Inspection
24 Sept 2026CamerasDepth camera ×2 · Optical camera ×2
24 Sept 2026LidarYes
24 Sept 2026Sensors3D LiDAR · Depth camera · Optical camera
24 Sept 2026ComputeIntel Core i5 (Platform Function), Intel Core i7 (User Development)
24 Sept 2026Battery capacity2250 Wh
24 Sept 2026Runtime300 min
Related · QuadrupedCompare with Unitree B2
Not affiliated with Unitree Robotics. JSON: /api/robots/unitree-b2 · Data CC BY 4.0 · Report an error